High-performance multi-core Edge AI computing platforms engineered for Off-Highway Machinery, Heavy Industrial Vehicles & Autonomous Ground Vehicles (AGVs), and Autonomous AGV / Mobile Robotics. Featuring heavy-duty circular connectors, deterministic real-time Linux container pipelines, and ruggedized environmental survivability.
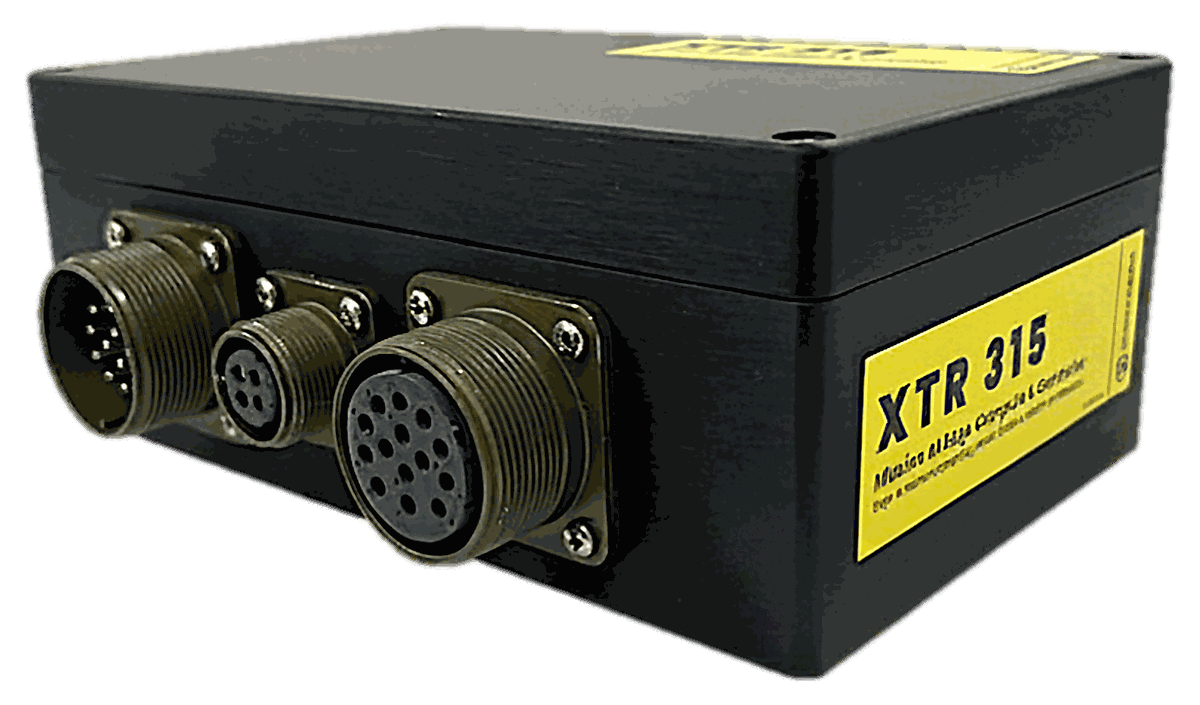
| Feature | XTR 315 Rugged AI Controller | Industrial Edge AI Gateway | Sensor Micro-Compute |
|---|---|---|---|
| Target Applications | Off-Highway, Heavy Machinery, AGV Robotics | Industrial Plants & Factory Cells | Direct Machine Mount (IGFO-100) |
| Processor Architecture | Multi-Core ARM Cortex-A72 / A53 + Hardware DSP | Quad-Core ARM Cortex-A53 / NXP i.MX8M | ARM Cortex-M55 + Helium DSP |
| AI / Vision Acceleration | Hardware NPU / Tensor Accelerator (Up to 10+ TOPS) | Dedicated NPU (2.3 TOPS) + OpenVINO | TinyML / Micro-TFLite (0.5 TOPS) |
| Connectors & Housing | Heavy-Duty Bayonet Circular Connectors, Milled IP67 Enclosure (IP69K Available via ODM) | 4x M12 Industrial Ports, Finned Aluminum | M12 8-Pin, IP67 Anodized Aluminum |
| Operating System | Real-Time Embedded Linux / Deterministic RTOS | Yocto Linux / Embedded Debian + Docker | FreeRTOS / Bare-Metal Deterministic |
| Protocols & Buses | CAN 2.0B / CAN FD, Gigabit Ethernet, RS-485 | OPC UA Server, MQTT Sparkplug B, EtherCAT | Modbus RTU, BLE, Single Pair Ethernet |
Engineered for deterministic execution in harsh physical domains: powering autonomous mobile logistics, tactical defense survivability, and precision multi-axis robotic actuation.
Central computing core for high-payload automated guided vehicles (AGVs) and warehouse mobile robots (AMRs). Executes 3D LiDAR SLAM, multi-camera obstacle detection, and real-time path replanning with sub-10 ms latency. Features dual isolated CAN FD interfaces and Gigabit Ethernet with hardware PTP IEEE 1588 synchronization to coordinate steering drives and safety laser scanners.
Hardened computing engine engineered for heavy-duty industrial vehicles, autonomous mining haulers, and field equipment sensor hubs. Designed for MIL-STD-810H Methods 514/516 shock and vibration survivability with rugged bayonet connectors. Operates reliably under severe mechanical shocks, industrial washdown, and extreme electromagnetic environments.
Deterministic motion controller running real-time Linux RT-PREEMPT kernel for 6-axis articulated robots, Cartesian gantries, and automated deburring cells. Executes microsecond motion interpolation, joint torque sensor feedback loops, and collision prediction while concurrently hosting containerized Docker vision models for robotic weld seam tracking and random bin picking.
IGNISFORMA provides custom carrier board design, FPGA integration, and qualification testing support at accredited partner laboratories.